An alarm
The measurement has left the range defined as normal. The cause is not named.
Reference
A practical account of how condition models estimate failure on industrial equipment: the signals they read, the families of calculation, and the point at which a score still needs a person.
Faultline starts somewhere else. A technician describes the symptom, and the device walks them through the next checks. This page is the sensor side of maintenance, kept separate so the two stay clear.
01
Nearly every method does the same three things. It turns a window of operation into numbers. It compares those numbers with a picture of healthy or failed behavior. It emits one of three results.
The measurement has left the range defined as normal. The cause is not named.
The window resembles a named fault: outer race, imbalance, rotor bar, or whatever the examples contained.
If the present trend continues, the asset is estimated to remain usable for a stated range of time.
02
Predictive maintenance is not a replacement for the program around it. It is one step on a ladder. Most facilities occupy more than one step at once, on different assets.
01
Repair after the stop. No model. The only data is the failed component.
02
Service on a calendar or an hour count, whether the part is worn or not.
03
Alarm when a measurement crosses a limit. The machine is usually still running.
04
Estimate the approach of a failure, and sometimes the life remaining, from a trend.
05
Recommend or start the next action. A person still has to confirm it against the machine.
03
An algorithm cannot recover a failure mode that the sensor never measured. Mounting direction, sample rate, and the operating regime are part of the method. A model trained on a steady full-load run will not transfer, unchanged, to a conveyor that starts and stops all shift.
Bearings, imbalance, misalignment, looseness, and gear mesh. The richest mechanical signal, and the one most often installed badly.
Rotor-bar damage, eccentricity, and some bearing tones, read from the drive without a separate accelerometer.
A late indicator. Useful as confirmation. A hot bearing has often already passed the point where a spectrum would have named it.
Gearboxes and hydraulics. Particle count and composition point at a wearing surface the vibration may not isolate.
Leaks, blockage, and pump wear. A trend in differential pressure is often the degradation path itself.
Starts, stops, overloads, and hours. Not a fault signature. The context that makes every other signal interpretable.
04
The families differ in how the numbers are built, and in what “healthy” is allowed to mean. A facility usually needs one of them for a given failure mode, not all seven.
UsesA single measurement against a published or site-set limit: overall vibration, temperature, current, or pressure.
ReturnsAn alarm once the value crosses the line.
Fails whenThe alarm is late, and it does not say why. Imbalance, a bearing, and a loose mount can all raise the same overall level.
UsesA baseline of normal operation. Control charts, exponentially weighted averages, and multivariate distance from that baseline.
ReturnsA signal that the process has drifted, often before a hard limit is reached.
Fails whenA change in speed, load, or product looks like a fault if the baseline was not taken in that regime.
UsesVibration or current transformed into frequency, often with order tracking and envelope detection. Bearing tones are computed from geometry and shaft speed.
ReturnsEvidence for a mechanism: outer race, inner race, rolling element, cage, gear mesh, or imbalance.
Fails whenWrong speed, wrong geometry, or a masked signal produces a confident and incorrect name.
UsesHand-built features, such as RMS, kurtosis, crest factor, and band energy, passed to a forest, a boosted tree, a support-vector machine, or an isolation forest.
ReturnsA fault class, or an anomaly score, learned from examples.
Fails whenLabeled failures are scarce and uneven. The model repeats the failure modes it was shown, and ignores the one it has not seen.
UsesA degradation path, a reliability model such as Weibull or Cox, or a match between the current trajectory and historical run-to-failure curves.
ReturnsAn estimate of useful life remaining, properly stated as an interval, not a date.
Fails whenThe next failure is assumed to resemble the ones in the history. A new mode, or a sensor that does not track the damage, makes the interval meaningless.
UsesA network trained on raw windows or spectra. Convolutional models classify. Autoencoders train on healthy data and score reconstruction error.
ReturnsA class or an anomaly score with less manual feature design.
Fails whenThe score still does not name a component. Regime shift and sensor drift raise the error without a fault.
UsesA degradation law, such as fatigue accumulation or thermal aging, with a model that corrects the residual the law does not explain.
ReturnsA forecast that remains usable when failure examples are few.
Fails whenAn incorrect physical assumption is worse than a simple limit. The residual cannot repair a wrong mechanism.
05
Overall vibration is a single number. A spectrum is that same signal sorted by frequency. If shaft speed is known, orders rather than raw hertz keep the peaks aligned when the machine changes speed. Envelope detection then looks for the repetition hidden inside a high-frequency ring: the rate at which a defect strikes.
For a rolling-element bearing, those rates are geometry. Outer-race, inner-race, ball, and cage frequencies depend on the number of rolling elements, shaft speed, and the ratio of element diameter to pitch diameter. A peak at the calculated outer-race frequency is evidence. It is not a remaining-life estimate, and it is not a work instruction.
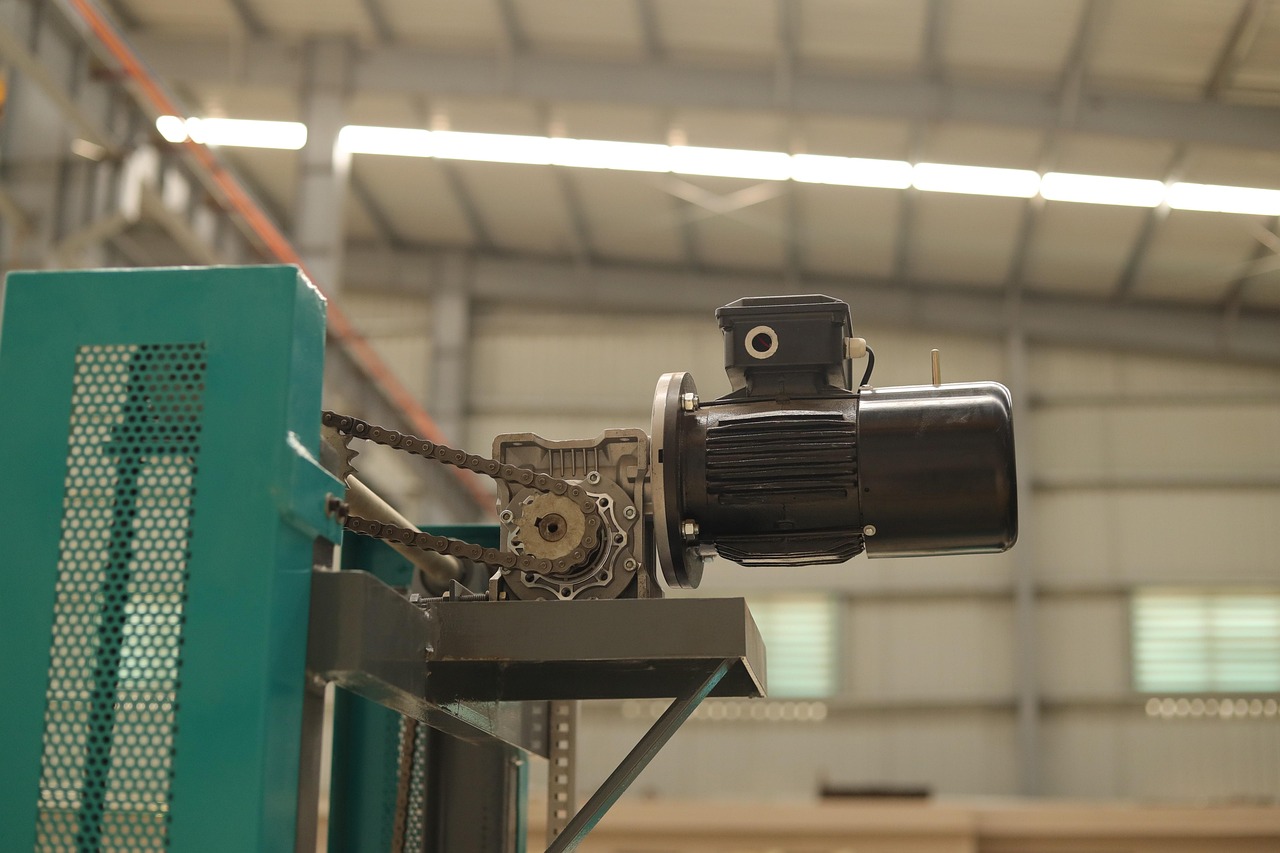
Current-signature analysis treats the motor’s electrical draw as a vibration sensor. Sidebands around line frequency can indicate broken rotor bars or eccentricity. Some mechanical tones appear in current as well, modulated by the air gap. The advantage is that the drive may already measure the current. The limit is the same as a spectrum: the speed must be known, and a peak still has to be interpreted by someone who knows the machine.
06
A window is labeled healthy, or as one of the faults the model was shown. The features may be built by an analyst — RMS, kurtosis, crest factor, band energy — or learned by a network from the raw signal. The training set is the product. Industrial failures are rare, and the ones that were written up are not a random sample of the ones that will occur.
The model trains only on healthy operation and scores how far a new window sits from it. Isolation forests and autoencoder reconstruction error are both versions of that idea. They are useful for “this does not look like the baseline.” They do not say which component to open. A change of product, speed, or sensor mounting raises the score without a fault.
A learned representation removes some of the manual feature work. It does not remove the requirement that the healthy data cover the regimes the asset actually runs, or that a high score be translated into a check a technician can perform.
07
Remaining-useful-life models treat damage as a path. A reliability model, such as a Weibull distribution or a Cox hazard model, uses age and operating stress. A similarity model finds historical runs that looked like the current one and reports how long those runs lasted. A physics model, such as fatigue accumulation or thermal aging, supplies the shape of the path when few failures have been recorded. A learned residual can correct the part of the path the law does not explain. It cannot repair a wrong mechanism.
The responsible output is a range, with the assumptions stated. A single date implies a precision the data usually do not support. The estimate is also conditional on the damage mode continuing. A new mode, or a sensor that does not track the damage, does not produce a narrower interval. It produces a different problem.
08
The calculation is the middle of a chain. Feature extraction may run on the drive or a gateway, because a raw vibration stream is too heavy to store continuously. Fleet comparisons and model updates usually stay on a historian. None of those locations completes the maintenance action.
01
A measurement at a known point, with a known direction and a sample rate that can see the fault.
02
A slice of operation long enough to estimate the feature, tagged with speed and load.
03
A limit, a spectrum rule, a classifier, or a life model. One of them, chosen for the failure mode.
04
An alarm, a component name, or a life interval, with the confidence stated.
05
A person, or a work order, that can act before the stop. The model does not complete this step.
Distribution equipment makes the last step concrete. A gearbox trend can be scheduled. A belt that walks off after a splice, or a photoeye that fails only on reflective totes, often has no degradation signal at all. Those are observed faults. A life model does not produce the next question.
09
Accuracy on a demonstration set is not the measure. The measure is whether the output changes a planned repair, at an acceptable rate of false alarms, on this facility’s equipment.
Was healthy operation recorded across the speeds and loads this asset actually runs?
Is a failure in the data a confirmed component fault, a work order, or a note?
Does the result name a component, or only a score that still requires a diagnosis?
Is the warning early enough to use a planned stop, or does it arrive with the failure?
What does a false alarm cost on this line, compared with a missed failure?
Can the person on the shift act without reconstructing the reasoning from another system?
A condition model is valuable when the asset is still running and the sensor represents the damage. Faultline is for the technician already standing at a stopped zone. On the Faultline device, they describe the symptom and get an ordered set of actions, with no sensor history required to begin.